· FUTURE CONCEPT
NOVA DeskA multimodal desk robot
A lens-like sensor head appears to float above a circular plinth on a rear support arc. Explore local AI workflows, a physical privacy control and a replaceable computing module.
Original design · Prototype validation pending
View the design poster ↗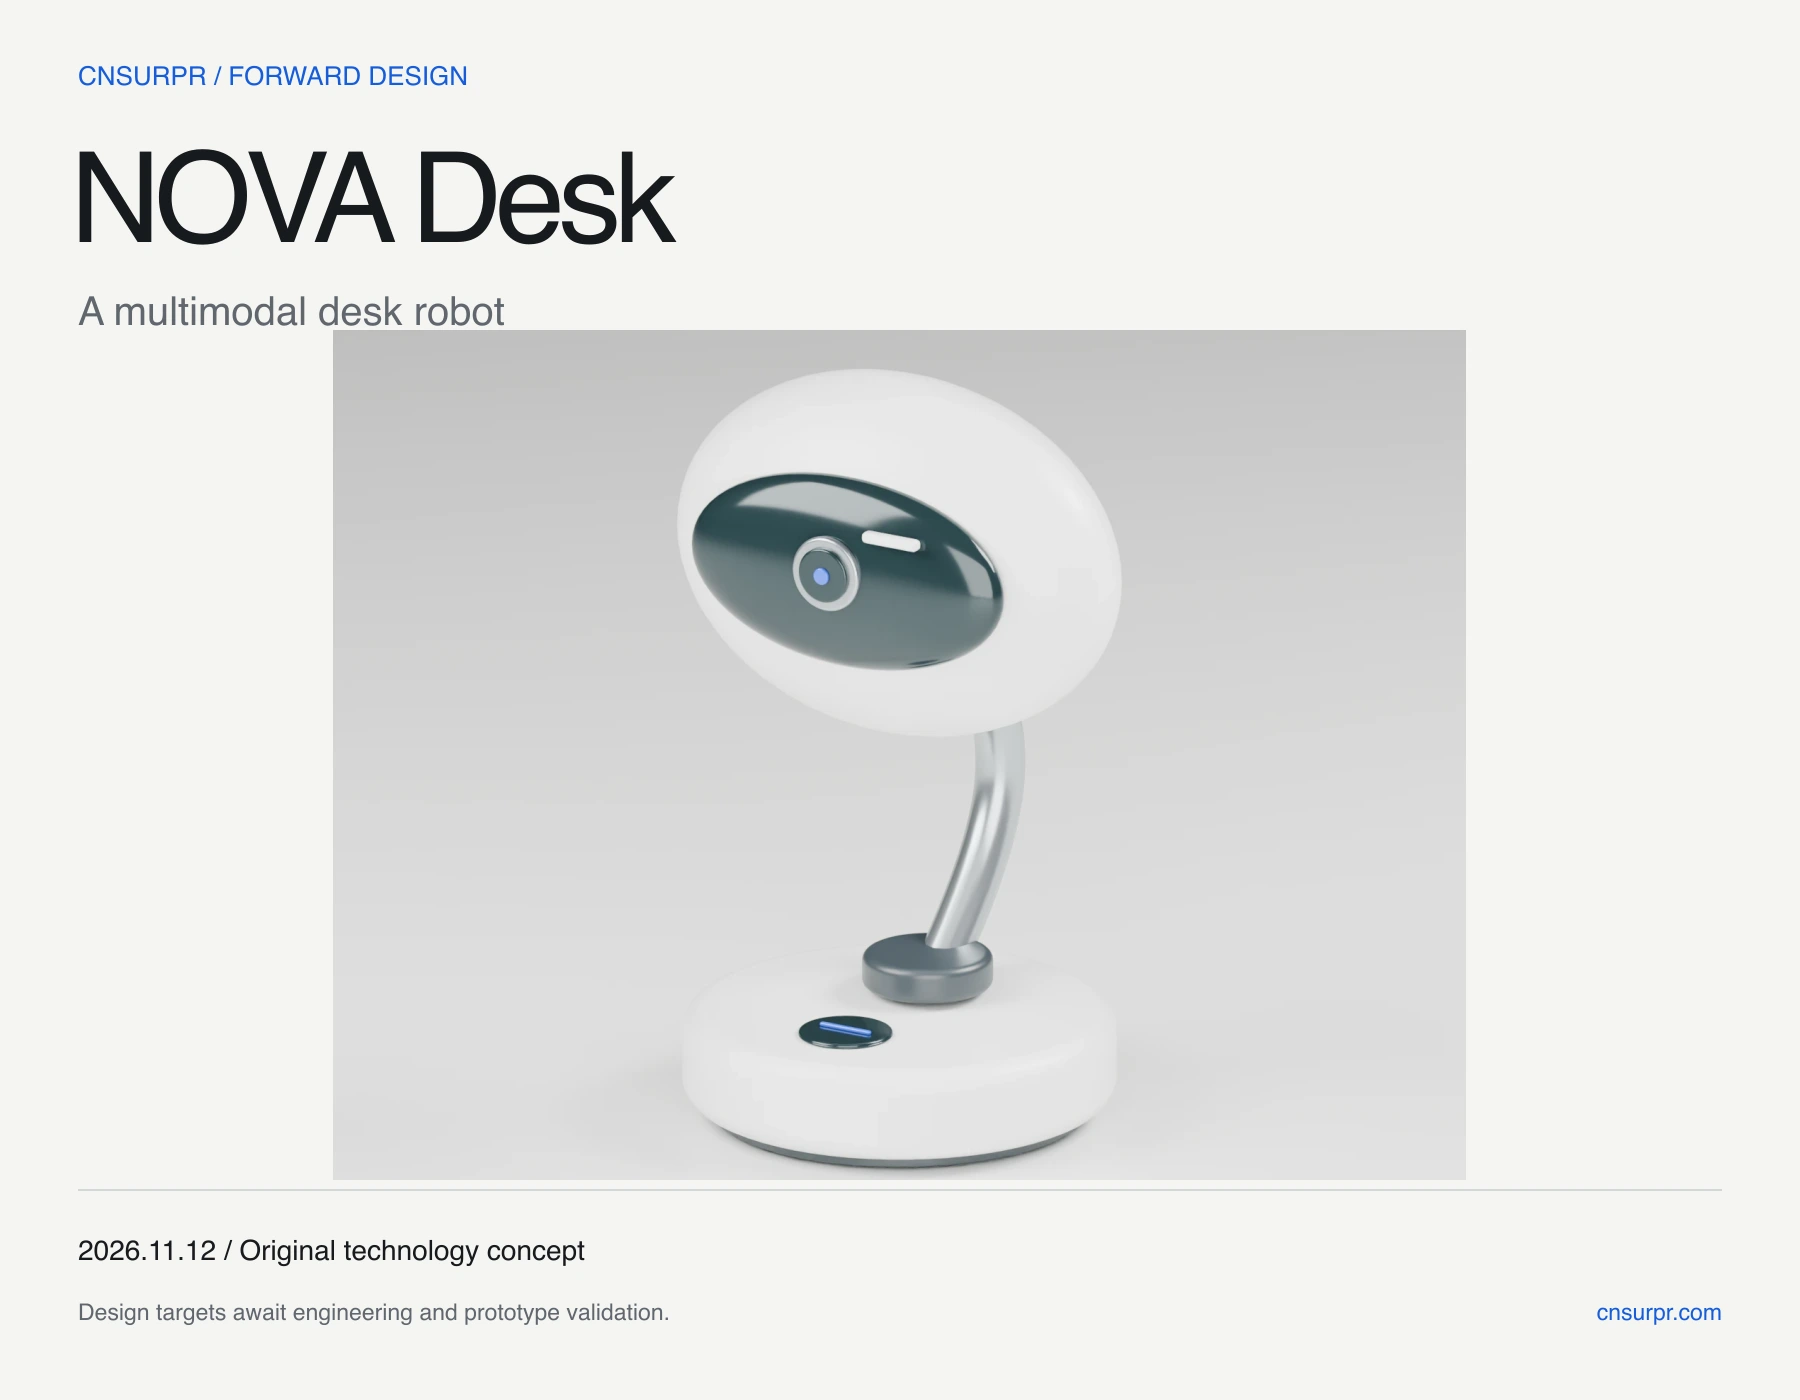
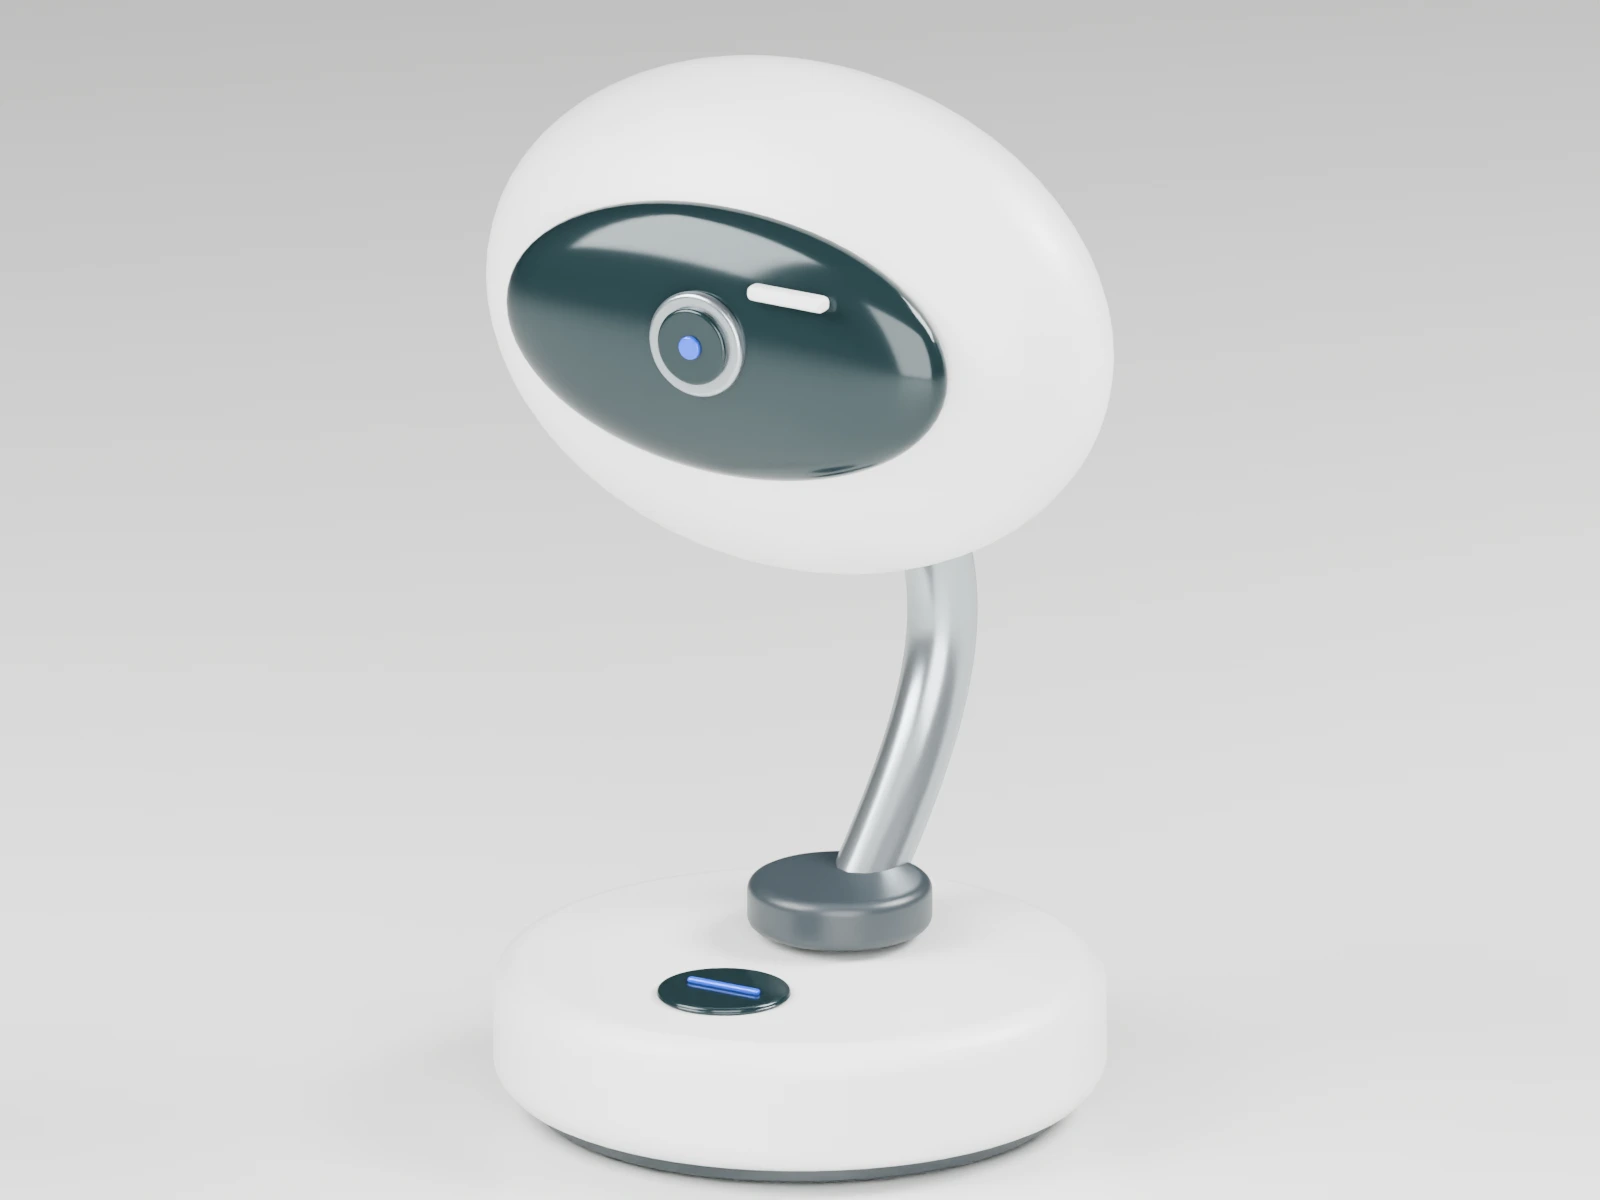 DESIGN STUDY · v0.1
Drag to orbit, or use the buttons. No automatic motion. Geometry illustrates an idea; it is not a validated assembly.
Why design ahead in this category?
Open robot software and deployable AI applications are shortening the path from a mechanism to a useful desk companion. Our design bet is on a compact platform that people can keep adapting, with explicit privacy controls.
Adjacent product installed base
≈10,000Reachy Mini developer report · 6 May 2026. Manufacturer/community disclosure, not an independently audited total.
Read source ↗Adjacent consumer demand
US + UKCasio reports Moflin sales expansion in Oct 2025 and demand exceeding supply in its FY2026 Q3 briefing. Different robot segment.
Read source ↗Open robotics reference
1,658Reachy Mini GitHub stars · 12 Nov 2026 snapshot. Last repository push 5 Nov; snapshot gives no star-growth rate.
Read source ↗The product advantage to test
The proposed design joins a serviceable sensor head, visible camera shutter and swappable compute bay. A focused application library and measured task completion could build product value. Its benefit over a screen or fixed camera remains a prototype question.
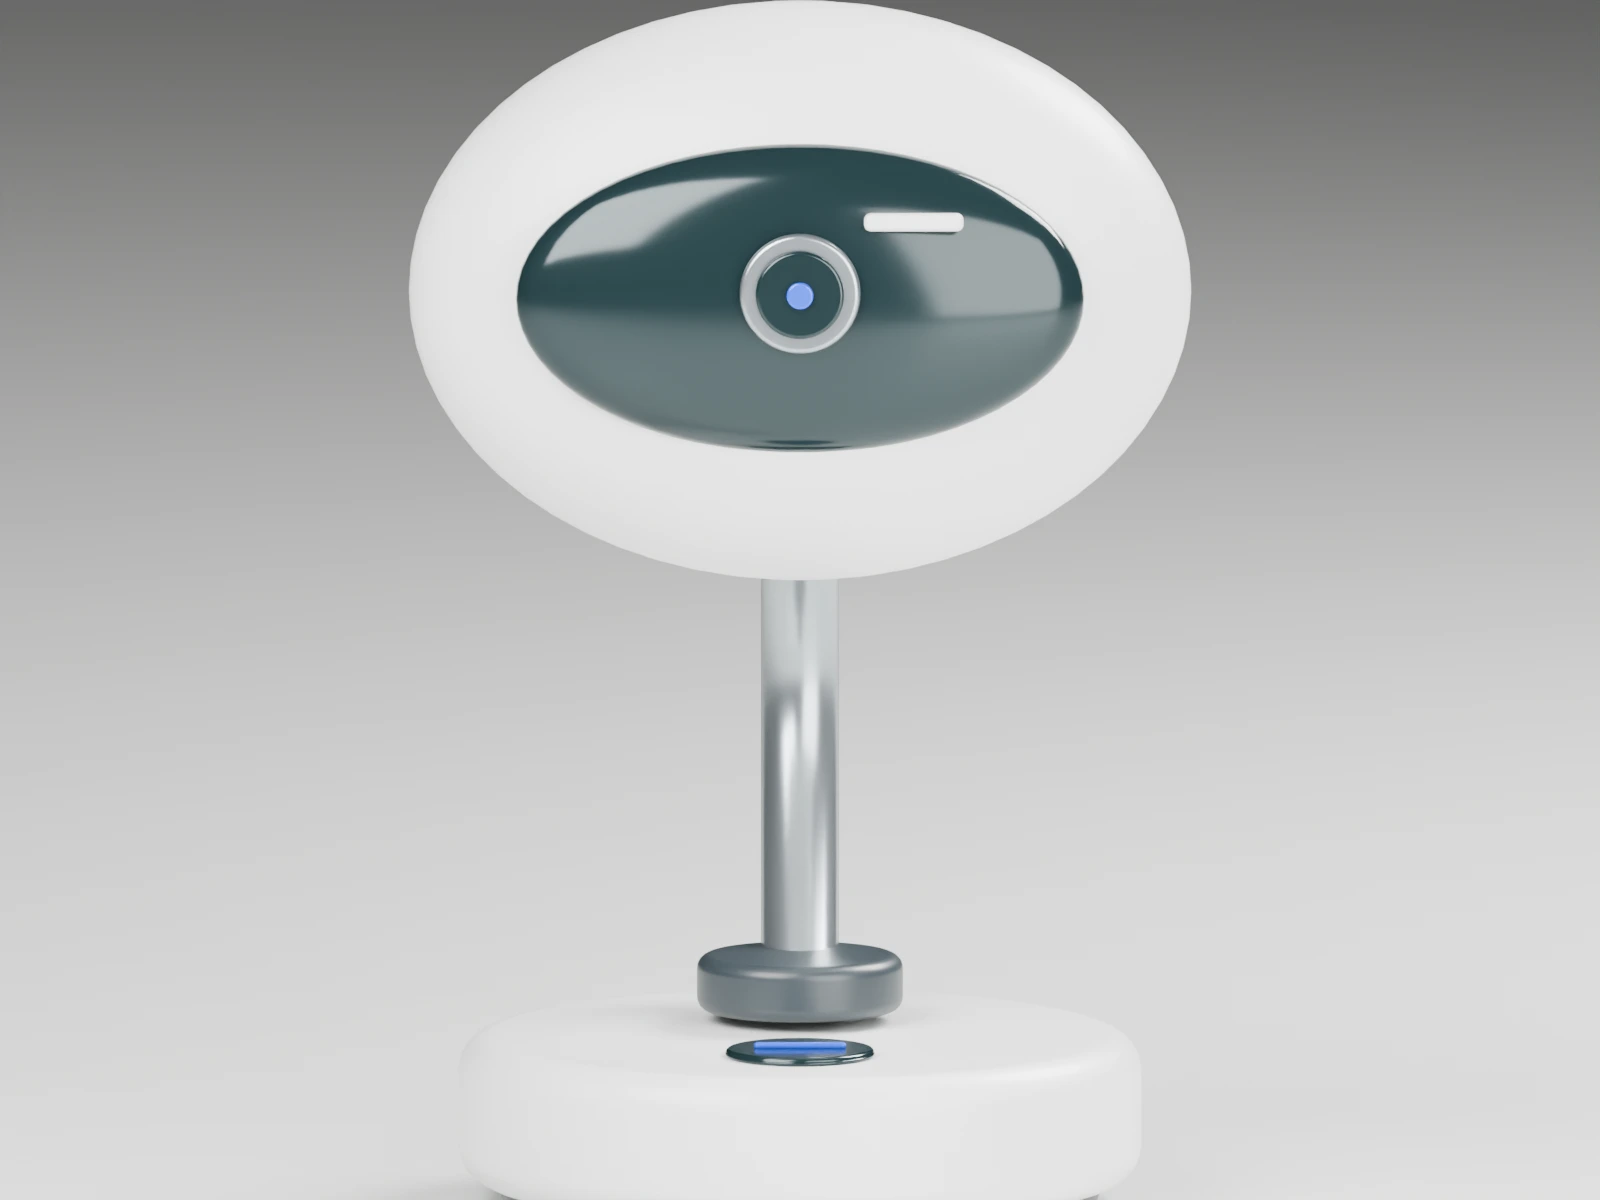
A directional interface
The head can face a speaker or a task area. Motion limits and acoustic performance await engineering.
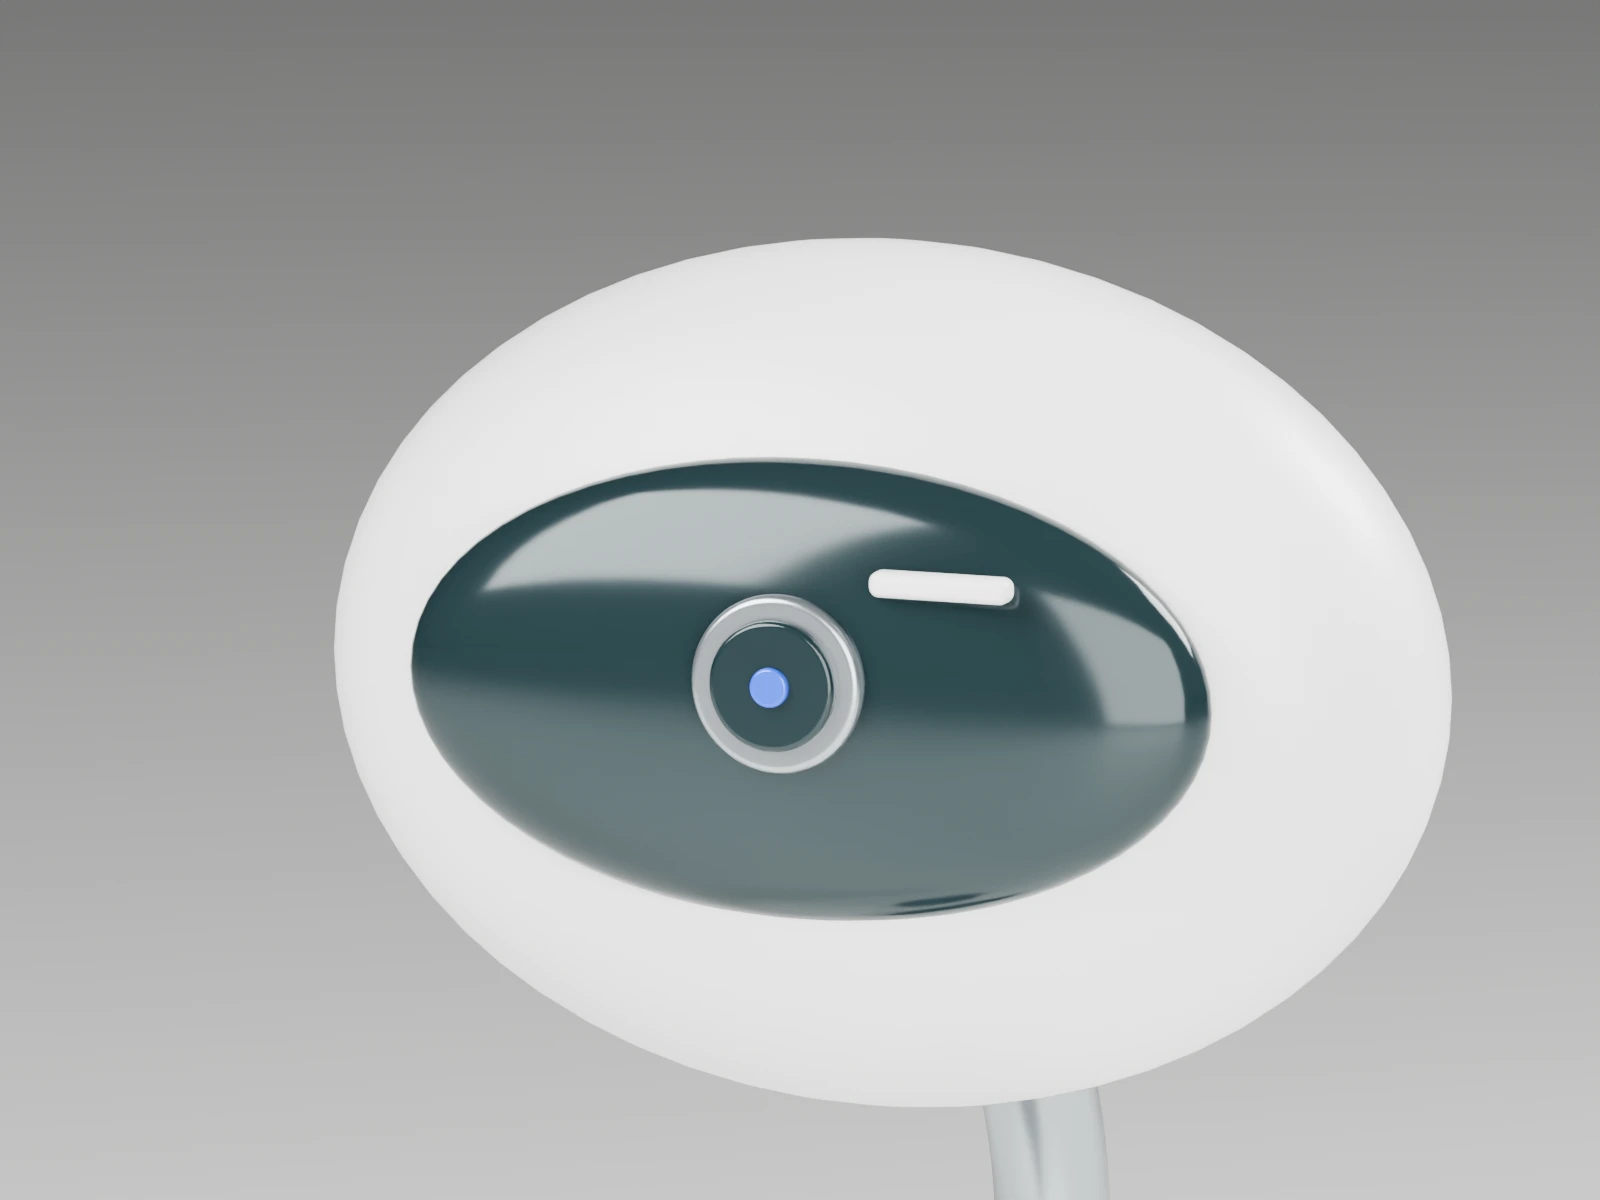
A replaceable sensor head
Camera, front panel and microphones are considered as a separate service assembly.
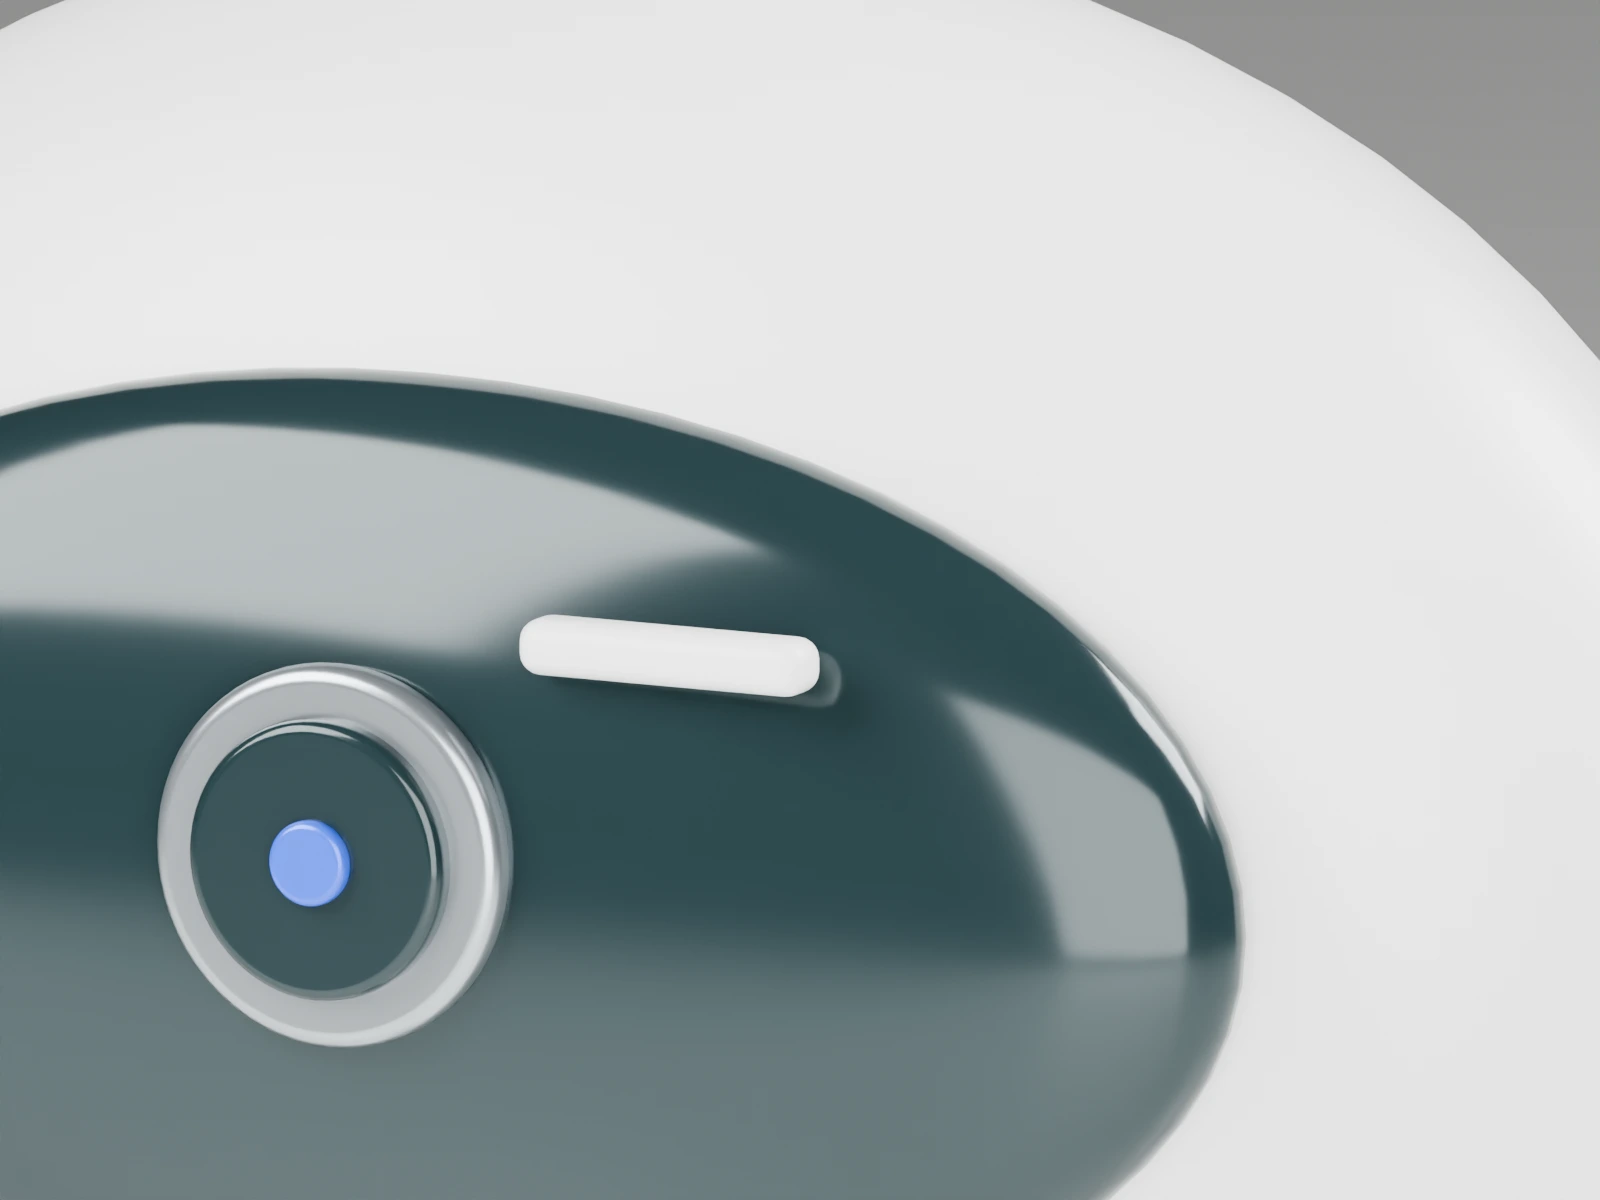
A physical camera control
A porcelain slider illustrates the proposed shutter position. Audio mute and sensor status need hardware validation.
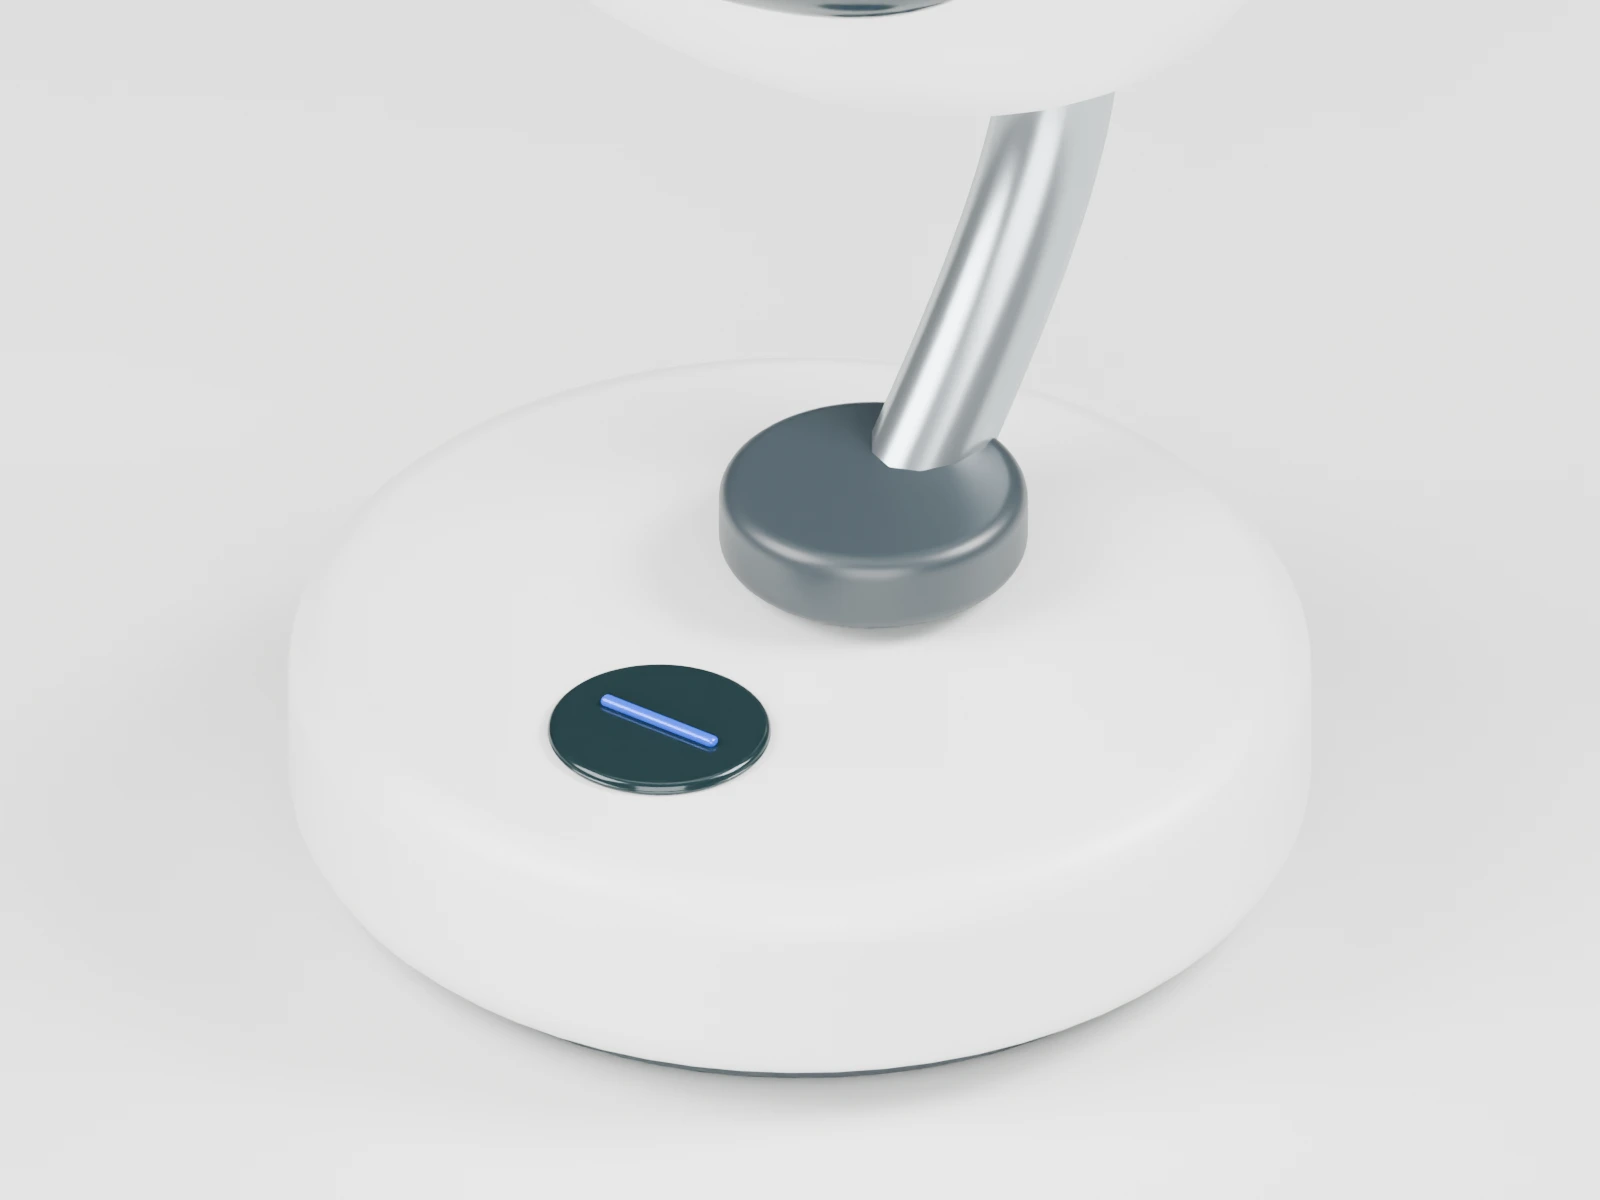
A stable powered base
Proposed weighted base, speaker grille and accessible control surface.
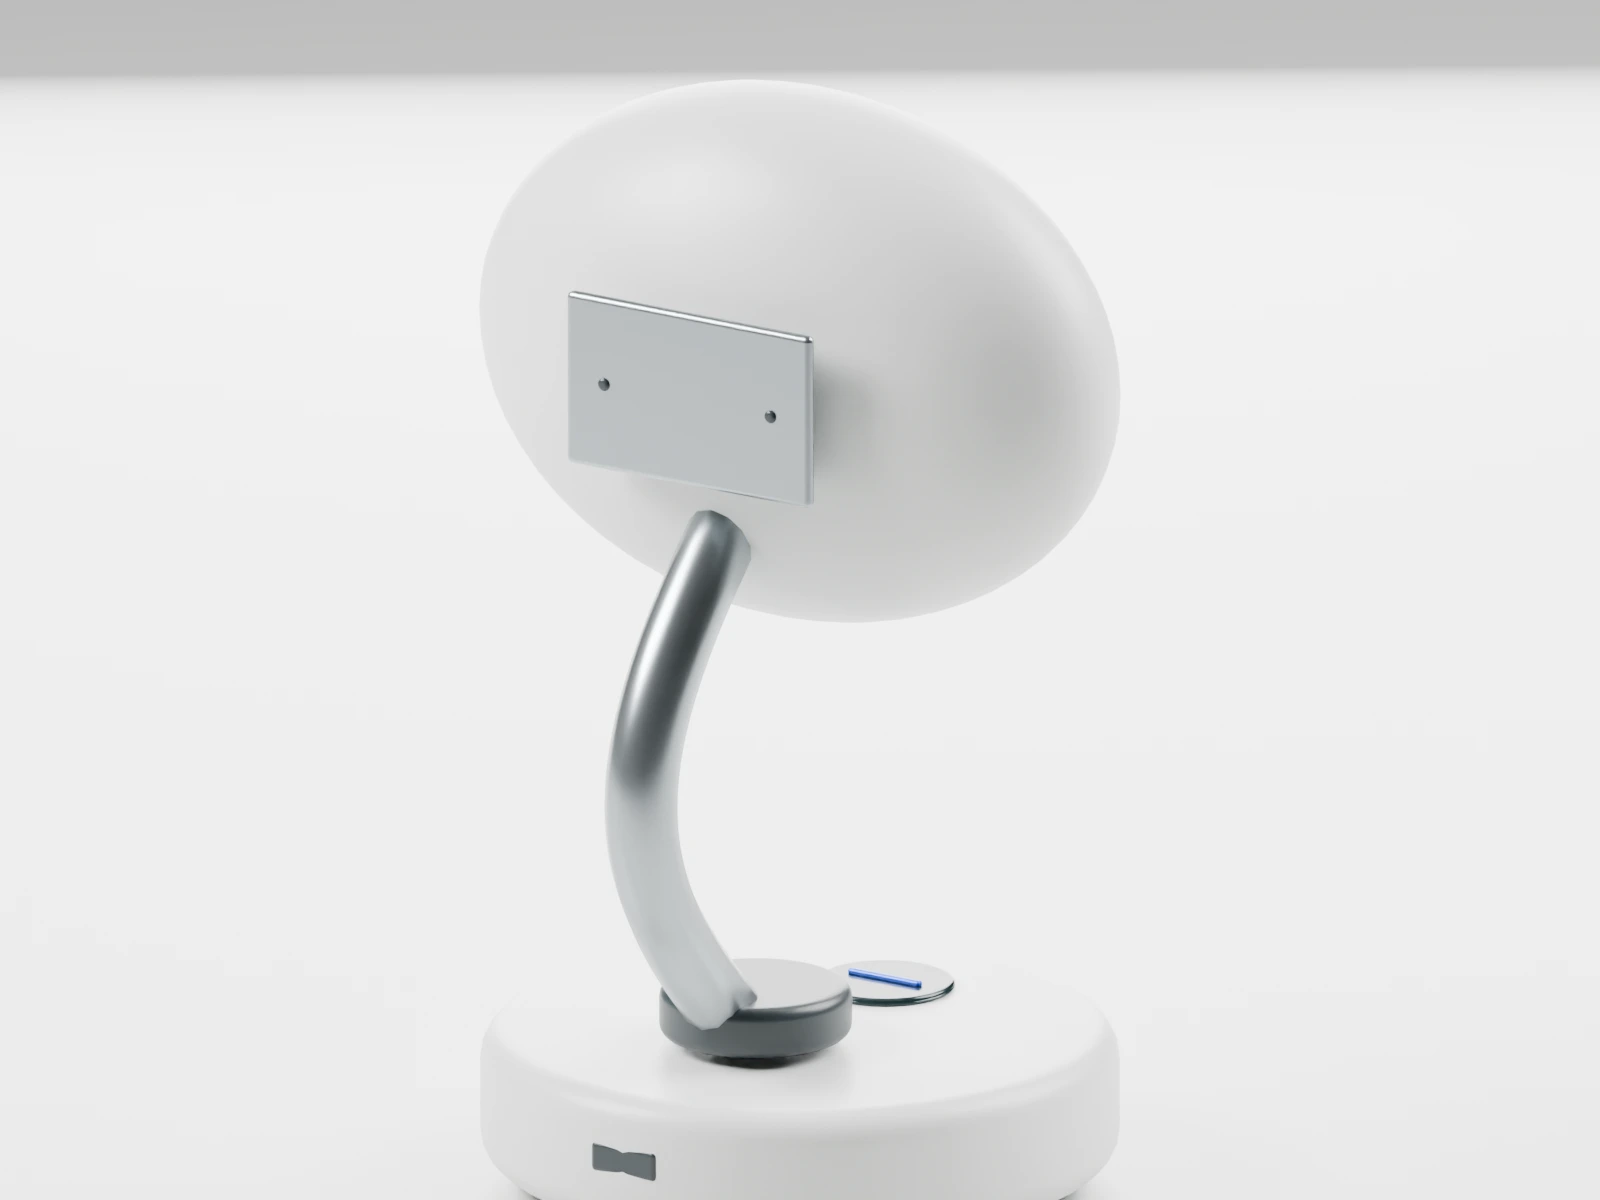
A compute service bay
The rear layout explores cable access and separation of sensing and compute.
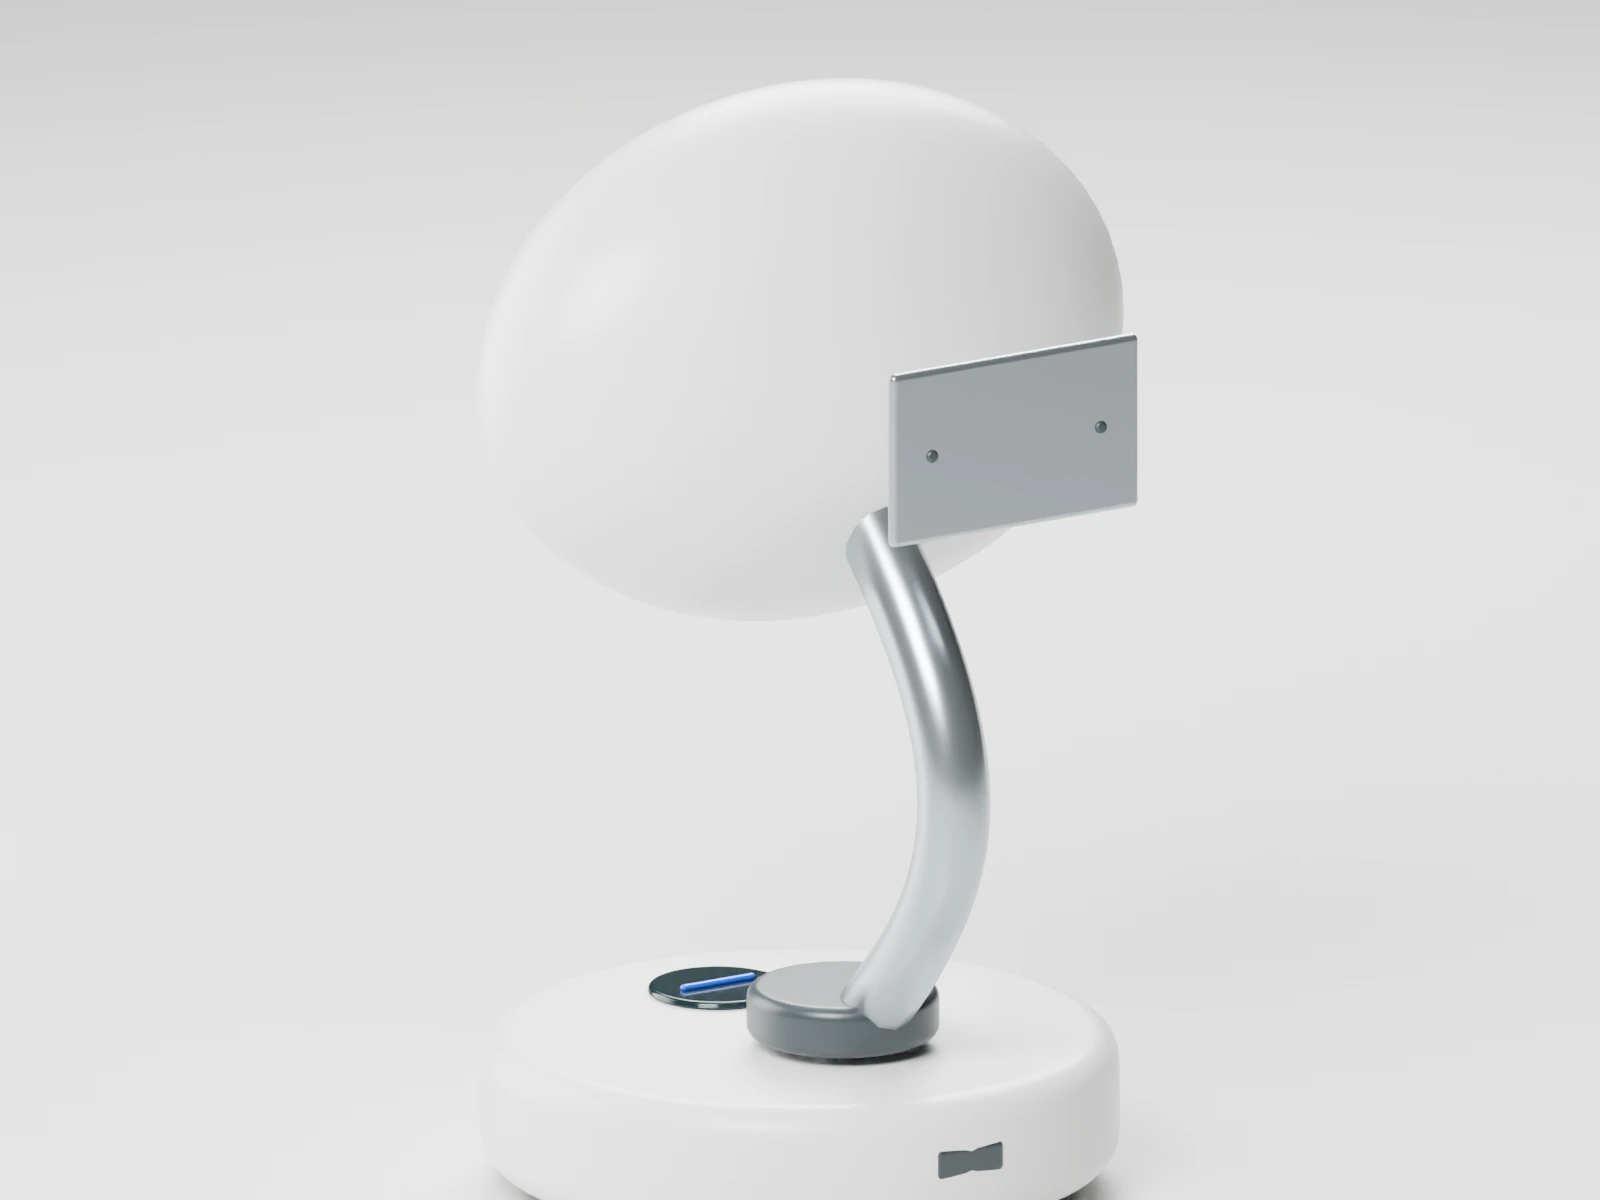
An enclosure that opens
Exploded parts illustrate access paths. No joint strength or thermal result has been established.
A development route grounded in hardware
Appearance envelope about 110 × 97 × 170 mm, external USB-C power with a ≤25 W input target. Camera, microphones, speaker and two geared motion axes are proposed. First evaluate host-computer inference, then an embedded compute module. Torque, noise, cooling, stability, pinch protection and inference performance remain open.
The next two planning windows
30–90 days: compare a few focused tasks with a fixed camera and computer. 3–6 months: measure weekly repeat use, response latency, noise and maintenance. Reduce scope if a moving head adds novelty without task value.
What could weaken the opportunity?
Reachy Mini has an existing app ecosystem. A desk robot also competes with a camera, smart speaker and ordinary computer software. Long-term utility, quiet motion and trustworthy local processing need proof. Public market signals here are narrower than the glasses data.
Questions before a sourcing brief
What can the design demonstrate today?
The images and interactive geometry demonstrate one consistent original appearance and service concept. Proposed functions, power, lifetime and production require prototype evidence. Price, MOQ and lead time remain unconfirmed.
How reliable is the growth forecast?
This is a forward design thesis informed by public shipment, issuer and developer evidence. These sources measure different populations. We will revisit the thesis after 30, 60 and 90 days, including counterexamples and product-use evidence.
How are search and AI discovery addressed?
The page answers product and sourcing questions with paired language URLs, dated evidence and consistent technical descriptions. The phrases below are research candidates whose search volumes remain unverified.
local AI desk robot · multimodal desktop companion · serviceable robot · private visual assistant
Evidence reviewed 2026-11-12
Nearly 10,000 units and 200+ apps reported for Reachy Mini. This is a dated, adjacent-product disclosure.
Hugging Face · 6 May 2026 ↗Demand and overseas expansion for Moflin. No NOVA sales or total desktop-robot market can be inferred.
Casio FY2026 Q3 · p16 ↗Open SDK reference under Apache-2.0. NOVA has its own original appearance and remains an untested concept.
Reachy Mini ↗Local inference engine reference under MIT. Model weights and device speed require independent evaluation.
llama.cpp ↗